Welcome to 6-Axis Control!
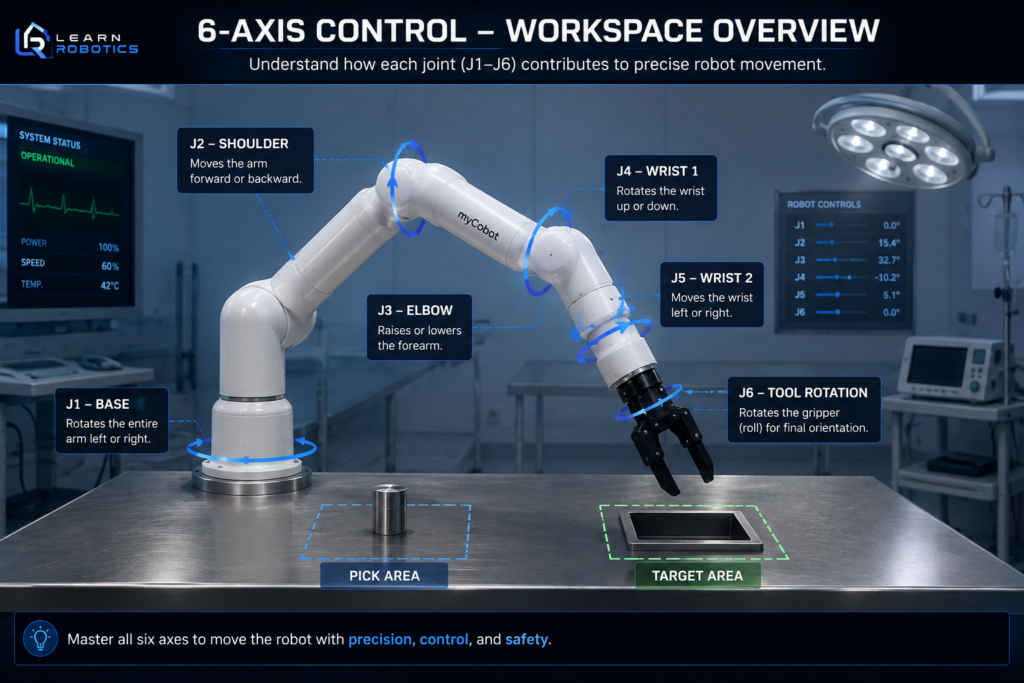
In this lesson, you will learn how the six joints of a robotic arm work together to control its position and orientation.
Each joint (J1–J6) controls a different part of the robot’s movement.
Your mission is to move the robotic arm through different positions while maintaining precise and controlled motion.
Pay attention to joint movement, gripper orientation, and safe positioning.
Complete this lesson to unlock 6-Axis Control – Mission 3.
Mission Objective
Mission Steps:
- Move the robotic arm to the starting position.
- Rotate J1 to align the robot with the target direction.
- Adjust J2 and J3 to position the arm above the object.
- Use J4 and J5 to maintain the correct wrist orientation.
- Use J6 to align the gripper precisely with the object.
- Lower the gripper slowly toward the object.
- Pick up the object while maintaining its orientation.
- Coordinate the six joints to move toward the target area.
- Position the object precisely above the target.
- Lower and release the object safely.
Success Criteria:
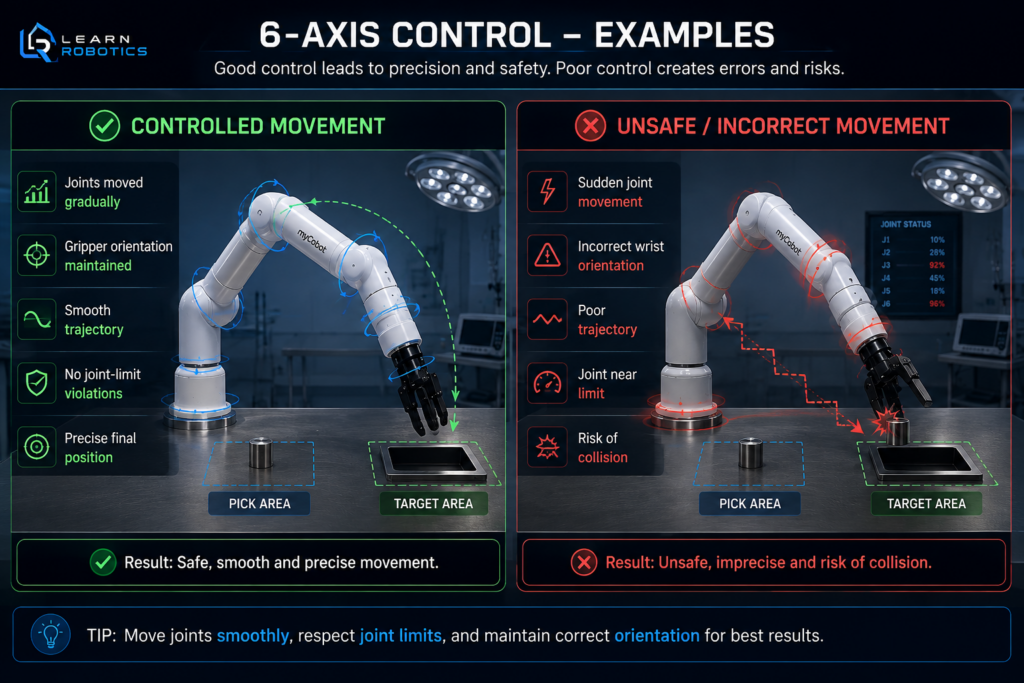
All joint movements must be smooth and controlled.
The gripper must maintain the correct orientation throughout the mission.
Avoid joint limits and collisions.
Control and precision are more important than speed.