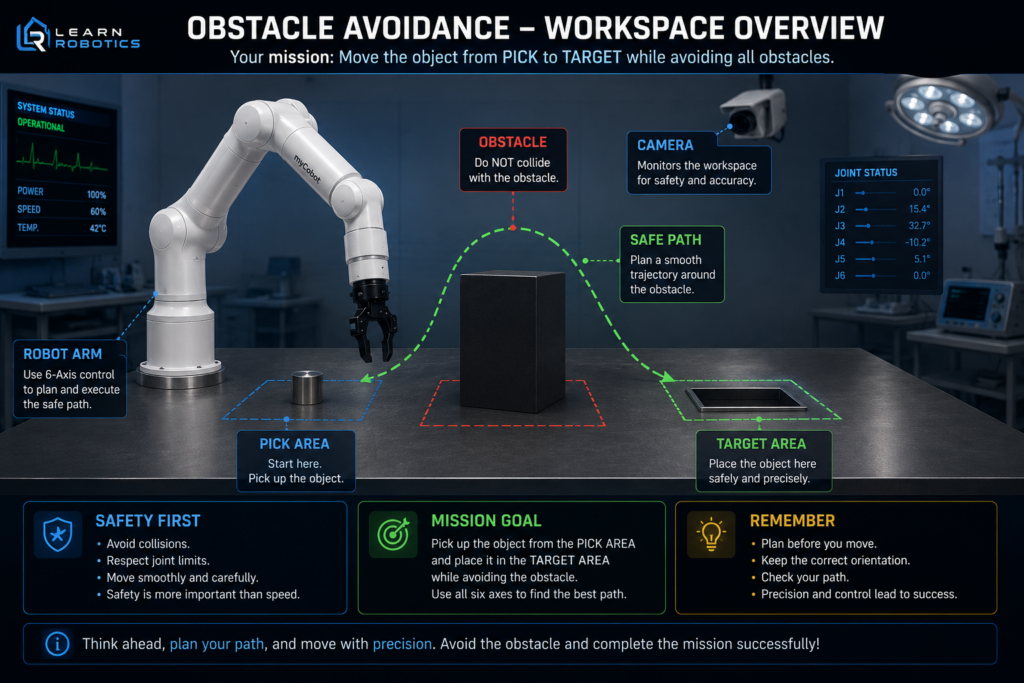
In this lesson, you will learn how to plan and execute a safe robotic movement around obstacles.
Your mission is to pick up the object and move it from the PICK AREA to the TARGET AREA without touching the obstacle.
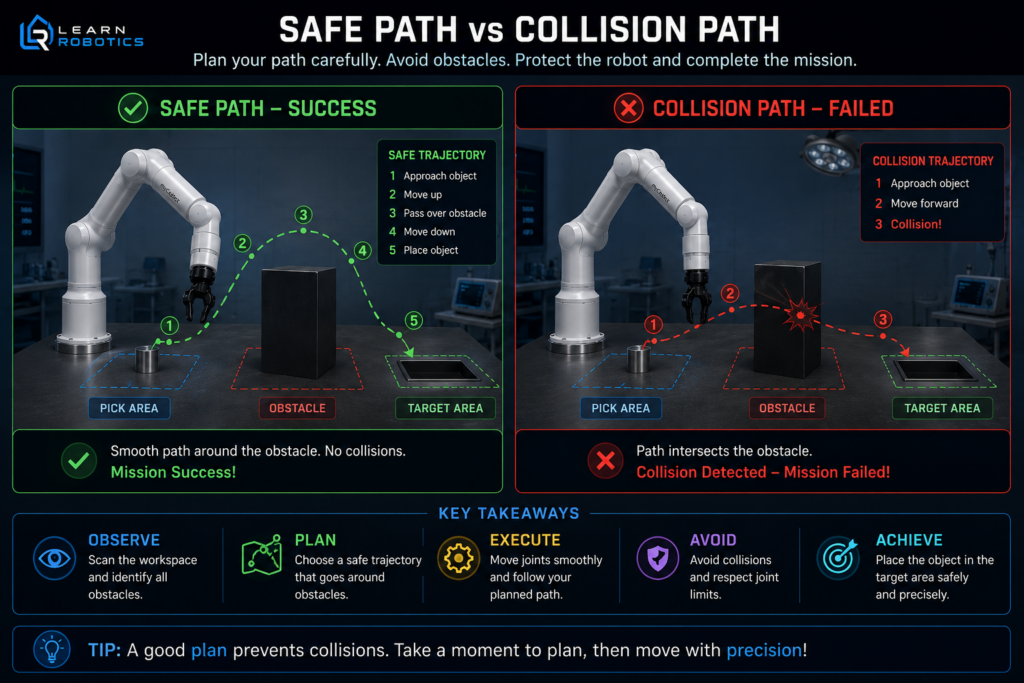
A direct path is not always a safe path. You must observe the workspace, plan the trajectory, and coordinate the robot joints to move around the obstacle.
Focus on safe path planning, smooth movement, correct gripper orientation, and collision avoidance.
Complete this lesson to unlock Obstacle Avoidance – Mission 4.
Mission Objective
Mission Steps:
- Observe the workspace and identify the obstacle.
- Locate the PICK AREA and the TARGET AREA.
- Move the robotic arm toward the object.
- Align the gripper carefully above the object.
- Pick up the object securely.
- Plan a safe trajectory around the obstacle.
- Move the object along the planned path.
- Maintain safe distance from the obstacle at all times.
- Position the object precisely above the TARGET AREA.
- Lower and release the object safely inside the target.
Success Criteria:
The robot must complete the mission without touching the obstacle.
The object must remain securely held during the movement.
The object must be placed completely inside the TARGET AREA.
No collisions. No drops. No joint-limit violations.
A safe and controlled path is more important than speed.